Celebrating 25 years of DDD's Excellence and Social Impact. ✖

Human Egocentric Video Dataset for Embodied AI and Robotics

Stereo egocentric video with synchronized head and hand pose, captured on mixed-reality hardware and ready for your training pipeline today.

Explore the Dataset

Conference Room

Kitchenette Pantry

Open Office Desk

Reception Desk

Our egocentric dataset is available to license immediately, delivering production-grade stereo video, synchronized head and hand pose, and VLA-ready annotations from real human manipulation tasks captured across real-world environments. 

rectangle 1 1
  • Rectified stereo video above 1080p with 21 to 26-joint hand tracking per hand
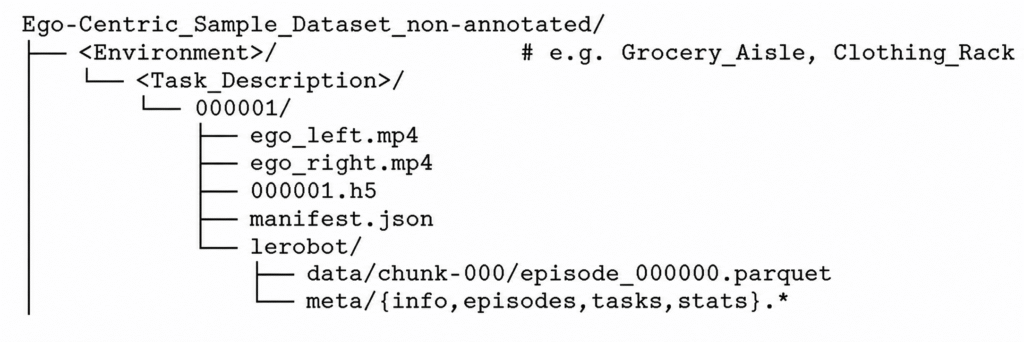
  • Delivered in HDF5 and LeRobot v2 formats for immediate pipeline ingestion
  • Commercial usage rights with PII removed at the point of capture
  • Purposeful manipulation episodes, so every clip earns its place in your training set

Access Dataset

Environment Task Frames Duration Download
Conference Room Distribute notepads and pens around a conference table 3,674 61.2
Conference Room Erase a whiteboard and rewrite a 3-row agenda 6,296 104.9
Conference Room Set up a water carafe and six glasses on the conference table 4,136 68.9
Conference Room Set up six chairs around a conference table 5563 93
Kitchenette Pantry Heat a lunch container in a kitchenette microwave 6,649 110
Kitchenette Pantry Pour hot water from a dispenser for instant tea 5350 107
Kitchenette Pantry Wipe down a microwave interior with a damp paper towel 4750 79
Open Office Desk Refill a self-inking stamp with new ink drops 3,734 62.2
Open Office Desk Replace a dry whiteboard marker tip cap and store in tray 4401 73
Reception Desk Sign a visitor into a paper logbook and issue a badge 3939 66

Explore our Egocentric Dataset Catalog

Robots learn manipulation best from real human demonstrations. Our ready-to-license, first-person data captures people doing real work, recorded with synchronized motion sensors, so your team can begin training right away instead of spending months building its own collection.

Industrial Workplace Video

Egocentric RGB footage of skilled work across nine real workplaces, including garment factories, furniture workshops, electronics and semiconductor labs, paper and textile mills, and household and retail settings.

iPhone Home Tasks

Everyday household tasks captured on iPhone, with depth, 3D hand tracking, IMU data, and camera calibration included in every clip.


Narrated Video with Transcripts

Workers describe what they are doing as they do it, and every clip comes with a transcript. This pairing of action and language is well suited to training vision-language-action models.

Calibrated Stereo

Calibrated global-shutter stereo video with a 300 Hz IMU, built for metric 3D reconstruction of hands and objects.

Stereo with Wrist Cameras

A head-level stereo view combined with a close-up camera on each wrist, capturing fine-grained detail of how hands interact with objects.

UMI Gripper Demonstrations

Handheld-gripper episodes recorded with the UMI interface, structured to map directly to robot actions.

Why Choose DDD Egocentric Dataset

ODD Analysis 4

Mixed-Reality Headset Hardware

Captured using Pico 4 Ultra, Apple Vision Pro, Meta Quest 3, and Project Aria, devices with on-board SLAM, inside-out tracking, and hardware-level hand and head pose pipelines built for highest quality and precision manipulation capture.

ODD Analysis 3

Stereo Video with Full Pose Telemetry

Every episode delivers rectified stereo video above 1080p at 60fps, per-frame 6DoF head pose, a 21 to 26-joint hand skeleton per hand in both camera and world frames, and IMU data. Frame-to-pose synchronization is within 10 milliseconds at p95 across every episode.

ODD Analysis 2

Pipeline-Ready Delivery

Every episode ships as rectified stereo MP4 files, a raw HDF5 pose file with the full per-frame schema, and a complete LeRobot v2 dataset with a 371-dimensional float32 observation state.

ODD Analysis 1

Annotated for the Reasoning Layer

Every episode carries a natural-language task description and temporal sub-task segments of one to five seconds, each naming the exact object and action involved.

Human Egocentric Video Dataset, Ready for Your Training Pipeline

Scroll to Top